
www.aero-defence.tech
16
'26
Written on Modified on
Deployment of Autonomous Unmanned Systems for Territorial Defense
Advanced robotic ground networks from Milrem Robotics integrate automated combat, electronic warfare, and situational awareness payloads to assume high-risk operational roles on modern frontlines.
milremrobotics.com
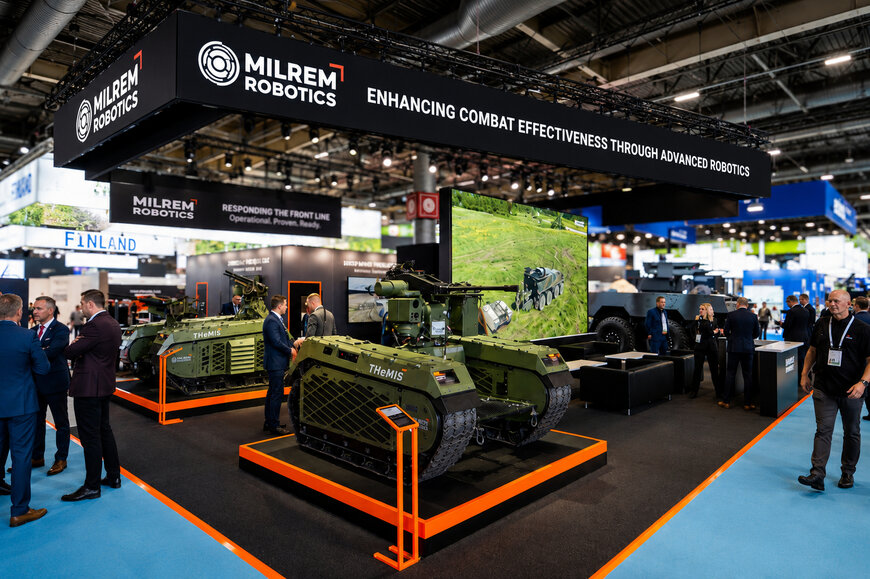
Modern asymmetric warfare and frontline operations place severe pressures on defending military forces. Engaging tactical vulnerabilities requires continuous perimeter surveillance, real-time threat detection, and prompt interception capabilities. Traditional defense infrastructures rely heavily on manned sentinel posts and crew-served weapons platforms. However, these traditional models expose personnel directly to continuous long-range precision fires and targeted loitering munitions.
Furthermore, the rapid proliferation of low-altitude hostile Unmanned Aerial Vehicles (UAVs) introduces significant process interruptions in defensive maneuvers. Standard short-range air defense systems often fail to isolate fine, highly dynamic drone targets in cluttered electronic environments. This technical gap leads to delayed target acquisition or a total failure of tactical communication signals, forcing units to operate without persistent overwatch.
Targets for Enhanced Readiness and Risk Mitigation
Transitioning to a layered, unmanned-first defense architecture directly addresses critical operational vulnerabilities. The primary improved operational goals include establishing a persistent defensive network where robotic platforms assume dangerous tactical duties. This methodology targets a significant extension of operational reach and high-readiness capacity while systematically reducing soldier exposure to primary kinetic threats. By replacing human operators with coordinated autonomous systems at hazardous perimeter sectors, military forces secure stable field synchronization. This optimization delivers predictable defensive response times without incurring personnel casualties.
Software Command Architectures and Cross-Platform Integration
To overcome the limits of standalone equipment, a unified command architecture orchestrates the defensive ground elements. The technical deployment is powered by the Autonomous & Robotic Control Suite (ARCOS), a modular command-and-control software framework developed by Milrem Robotics. ARCOS functions as the central logic node, unrolling a standardized interface to coordinate multi-vehicle configurations and diverse payload distributions. The software suite integrates into broader battle management systems, linking payload data streams and eliminating network latency across manned and unmanned divisions.
The primary hardware node within this interconnected network relies on the THeMIS Unmanned Ground Vehicle (UGV). Updated with field lessons from its deployment in Ukraine since 2022, the platform serves as a mobile foundation for specialized hardware integrations.
For remote fire support, the UGV incorporates the dual-Buria remote weapon station developed by Frontline Robotics, allowing units to engage enemy positions from protected distances. For counter-UAS use cases, the platform integrates the EOS R400 Slinger Counter-UAS Remote Weapon Station. This automated sub-system is equipped with a 30x113 mm automatic cannon and dedicated proximity-fused ammunition. The system is engineered to detect, track, and kinetically engage hostile drone targets at engagement ranges extending beyond 1,000 meters.
For heavy tactical operations, the architecture deploys the HAVOC Robotic Combat Vehicle (RCV). This platform relies on an 8x8 hybrid-electric chassis that delivers an optimal multi-physics balance of off-road mobility and silent watch persistence. The HAVOC architecture carries an integrated 30x113 mm automatic cannon, Short-Range Air Defense (SHORAD) missile components, and dedicated electronic warfare jamming kits to suppress hostile data transmission. Persistent aerial overwatch is secured by an Elistair Khronos tethered UAV, which maintains continuous elevation to feed stable reconnaissance data directly to the ARCOS command suite.
Engineering Modular Criteria and Standardization Compliance
The modular design language of the THeMIS and HAVOC platforms ensures technical flexibility from low-rate pilot evaluations to large-scale industrial defense deployments. This open architecture facilitates the parallel integration of diverse partner sub-systems showcased at Eurosatory in June 2026. These modular payloads include the TerraHawk Remote Weapon Station by MSI, the Flexible Mission Platform (FMP) by Moog, and KNDS’ modular Intelligence, Surveillance, and Reconnaissance (ISR) payload capsule, developed in cooperation with Thales France.
The open mechanical layout and electronic standard interfaces ensure that these components link into process piping without dead zones or non-standard protocols. This structural adaptability prevents integration errors, secures geometric part tolerances, and allows rapid field swapping of modular assets based on evolving threat parameters.
Objective Lifespan and Operational Lifecycle Performance
Transitioning to an inline, automated robotic network yields quantifiable operational benefits across long lifecycles. Real-time data processing through the ARCOS software suite optimizes fuel consumption and lowers maintenance cycles. The 8x8 hybrid-electric chassis layout reduces the acoustic and thermal signatures of the vehicle during passive tracking phases. This design saves energy compared to heavy conventional internal combustion powertrains and keeps the vehicle's electronic signature signature negligible within the overall defense energy budget.
To ensure low maintenance overhead, the modular platforms protect complex electronics with retrofittable control enclosures featuring on-board diagnostic verification. This design isolates components from vibration damage during high-intensity operations and guarantees long-term material reusability, minimizing operational scrap and providing a robust baseline for multi-theater defense rollouts.
Additional Context
In the global defense sector, the operational benchmark for unmanned ground vehicles is evaluated by payload versatility, software scalability, and signature management. When evaluated against alternative market systems, such as Rheinmetall’s Mission Master or General Dynamics’ robotic combat vehicle platforms, Milrem Robotics’ architecture distinguishes itself by leveraging the open-architecture ARCOS control engine. This configuration abstracts the underlying control software from specific weapon payloads, allowing the native integration of third-party platforms without specialized software patches. Furthermore, the deployment of a validated hybrid-electric drivetrain on the heavy HAVOC 8x8 platform yields significant acoustic mitigation during persistent watch operations, a metric rarely matched by conventional thermal powertrains in competing heavy robotic combat vehicle classes.
Edited by Sucithra Mani, Induportals editor – adapted by AI.
www.milremrobotics.com
