
www.aero-defence.tech
20
'26
Written on Modified on
Lunar Infrared Payload Integration for Planetary Exploration
NASA and the University of Arizona integrated specialized positioning hardware from Rocket Lab USA to enable high-resolution thermal terrain mapping on the lunar surface.
www.rocketlabusa.com
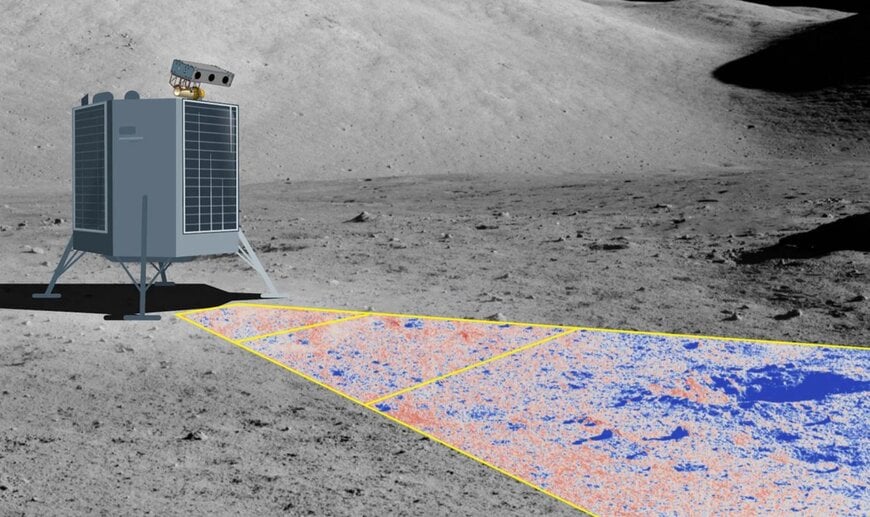
NASA, the University of Arizona, and Rocket Lab USA are collaborating to deploy an infrared imaging payload to map lunar terrain under the Artemis program. The scientific payload, designated EMILIA-3D (Emission Imager for Lunar Infrared Analysis in 3-D), generates three-dimensional thermal models of lunar regolith to support surface navigation, landing site characterization, and planetary exploration infrastructure.
Operational Roles and Technical Objectives
Mapping the lunar surface requires continuous optical operations across thermal shifts of 250°C and persistent solar radiation. Addressing these operational parameters required integrating specialized robotic avionics capable of maintaining precise orientation without thermal distortion.
The project divides responsibilities across research, hardware development, and mission management:
- The University of Arizona leads the scientific research and instrument payload architecture under the direction of Sarah Sutton.
- Rocket Lab USA, through its Rocket Lab Robotics division, engineered and supplied the integrated single-axis instrument gimbal mechanism.
- NASA oversees mission selection and integration within its broader lunar exploration initiative.
Technical Architecture of the Gimbal System
The EMILIA-3D system relies on a single-axis instrument gimbal developed by Rocket Lab Robotics to direct the infrared camera during scanning sequences. The subsystem functions as a fully integrated avionic and positioning unit engineered for spaceborne motion control.
Key functional elements of the system include:
The EMILIA-3D system relies on a single-axis instrument gimbal developed by Rocket Lab Robotics to direct the infrared camera during scanning sequences. The subsystem functions as a fully integrated avionic and positioning unit engineered for spaceborne motion control.
Key functional elements of the system include:
- Single-axis scanning motion control: Actuates the imaging sensor along defined angular paths to capture continuous frames required for photogrammetric 3D reconstruction.
- Environmental resistance: Hardened drive electronics and actuators operate across surface temperature fluctuations of up to 250°C (450°F) while resisting space radiation degradation.
- High-precision pointing: Stabilizes the infrared camera assembly to eliminate positional drift, ensuring repeatable spatial data for thermal modeling.
Mission Deployment and Planetary Applications
The EMILIA-3D payload will deploy directly to the lunar surface to evaluate regolith density, physical composition, and subsurface thermal properties. By providing volumetric thermal models, the data directly informs future landing systems, robotic pathfinding, and autonomous lunar rovers such as NASA's CADRE platforms.
The engineering integration follows previous space systems deployments by Rocket Lab Robotics, including robotic arms and mechanisms utilized on NASA's Mars Perseverance rover, as well as the 2022 deployment of the CAPSTONE spacecraft into cislunar transfer orbits.
Edited by Evgeny Churilov, Induportals Media - Adapted by AI.
www.rocketlabcorp.com
The EMILIA-3D payload will deploy directly to the lunar surface to evaluate regolith density, physical composition, and subsurface thermal properties. By providing volumetric thermal models, the data directly informs future landing systems, robotic pathfinding, and autonomous lunar rovers such as NASA's CADRE platforms.
The engineering integration follows previous space systems deployments by Rocket Lab Robotics, including robotic arms and mechanisms utilized on NASA's Mars Perseverance rover, as well as the 2022 deployment of the CAPSTONE spacecraft into cislunar transfer orbits.
Edited by Evgeny Churilov, Induportals Media - Adapted by AI.
www.rocketlabcorp.com
